seveibar/nema17-stepper-motor-driver-tmc2209-usb-pd
RP2040-based USB-C PD stepper-motor controller with TMC2209 drive, AS5600 position feedback, TMP102 thermal shutdown, current/voltage telemetry, RGB status LED, and protected buzzer alarm circuitry.
- Version
- 0.2.0
- License
- unset
- Stars
- 0
scripts/route.ts
import { AutoroutingPipelineSolver7_MultiGraph } from "@tscircuit/capacity-autorouter";
import { readFileSync, writeFileSync } from "node:fs";
const path = process.argv[2] ?? "routing/input.simple-route.json";
const input = JSON.parse(readFileSync(path, "utf8"));
const solver = new AutoroutingPipelineSolver7_MultiGraph(input, {effort: 2});
// The pinned TraceSimplificationSolver ignores its declared iterations option.
// Use its public loop limit before its first step. This preserves the routed
// geometry; the downstream width and both DRC repair passes remain enabled.
let phase = "";
while (!solver.solved && !solver.failed) {
  if (solver.traceSimplificationSolver) {
    solver.traceSimplificationSolver.MAX_SIMPLIFICATION_PIPELINE_LOOPS = 0;
    if (solver.traceSimplificationSolver.simplificationPipelineLoops !== 0) {
      throw new Error("Simplifier ran before bypass was installed");
    }
  }
  solver.step();
  const next = solver.getCurrentPhase();
  if (next !== phase) { console.log(next); phase = next; }
}
if (solver.failed) throw new Error(solver.error ?? "Routing failed");
writeFileSync("routing/route-plan.json", JSON.stringify({
  expectedInput: input,
  traces: solver.getOutputSimplifiedPcbTraces(),
}, null, 2));
console.log("Saved candidate routes. Run build and inspect unfiltered DRC.");
Related Packages
 More from this authorseveibar/1206_x4This code defines a PCB footprint for an 8-pin 1206-sized resistor network with surface-mount pads arranged on both sides in a compact rectangular package.
 Similar packageimrishabh18/rp2040-motor-controllerAn RP2040-based NEMA17 stepper-motor controller with USB-C programming and PD motor-power negotiation, DRV8825 dual H-bridge drive, current/temperature telemetry, protected power filtering, status RGB LED, buzzer alarm, and optional magnetic encoder.
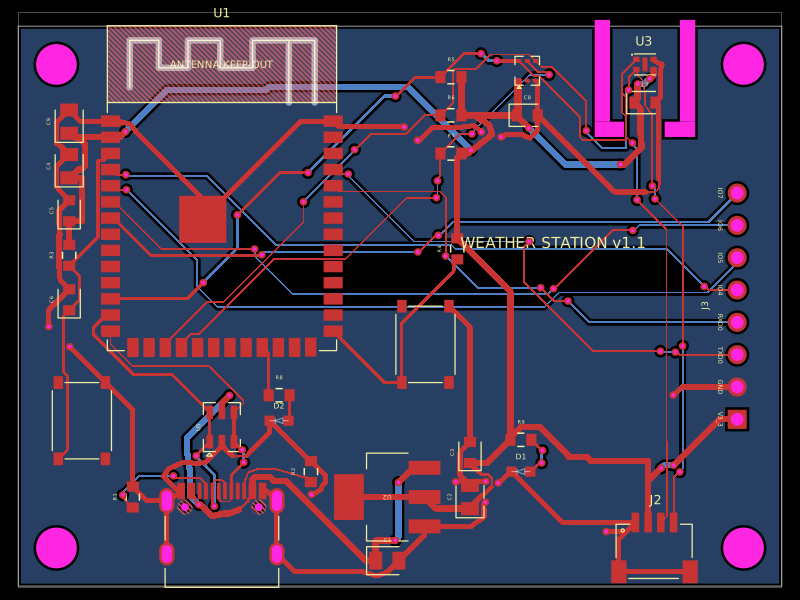 Discover something newolivergrabinski/tscircuit-weatherA 60×44 mm ESP32-S3 Wi‑Fi/BLE weather-station PCB with USB‑C power, 3.3 V regulation and ESD protection, temperature/humidity and UV/light sensors, status LEDs, buttons, Qwiic I²C expansion, debug GPIO header, and a printable enclosure.