mohan-bee/compact-pir
Compact 3.3 V ESP8684 wireless motion/GPIO breakout board with LiPo regulation, 40 MHz crystal, U.FL antenna matching, digital PIR sensor, switched LED, decoupling, and dual 10-pin headers.
- Version
- 1.0.2
- License
- unset
- Stars
- 0
firmware/main/motion_logic.h
#pragma once

#include <stdbool.h>
#include <stdint.h>

typedef struct {
    uint64_t boot_ms;
    uint64_t last_motion_ms;
    bool settled;
    bool seen_motion;
} motion_state_t;

static inline bool motion_update(motion_state_t *state, uint64_t now_ms,
                                 bool pir_high, uint64_t settle_ms,
                                 uint64_t hold_ms)
{
    // Unsigned elapsed times remain correct across the millisecond counter wrap.
    if (!state->settled) {
        if ((uint64_t)(now_ms - state->boot_ms) < settle_ms) {
            return false;
        }
        state->settled = true;
    }
    if (pir_high) {
        state->last_motion_ms = now_ms;
        state->seen_motion = true;
    }
    if (state->seen_motion &&
        (uint64_t)(now_ms - state->last_motion_ms) < hold_ms) {
        return true;
    }
    state->seen_motion = false;
    return false;
}
Related Packages
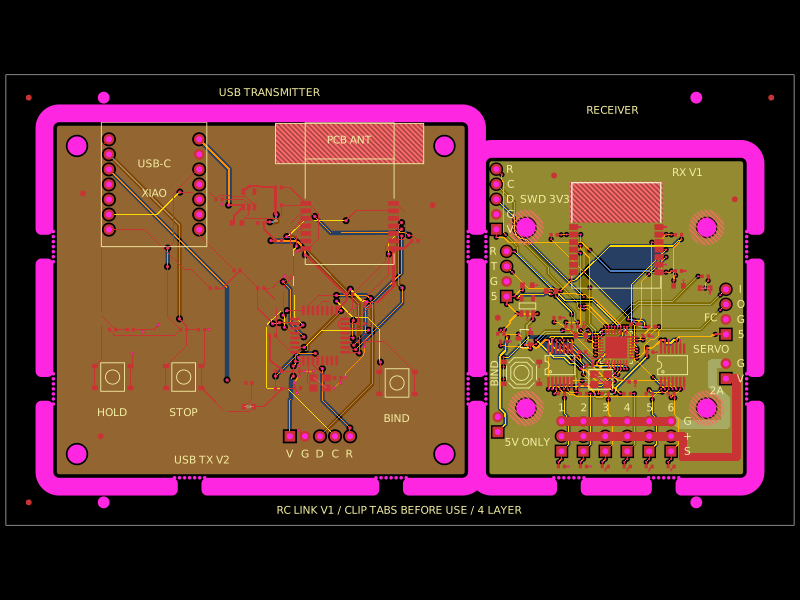 More from this authormohan-bee/rc-link-breakaway-panelA four-layer RC link panel combining an STM32/E28 2.4‑GHz transmitter with USB-RP2040 socket and an STM32/E28 receiver providing six buffered PWM servo outputs, regulated 3.3‑V power, headers, controls, and protection/decoupling.
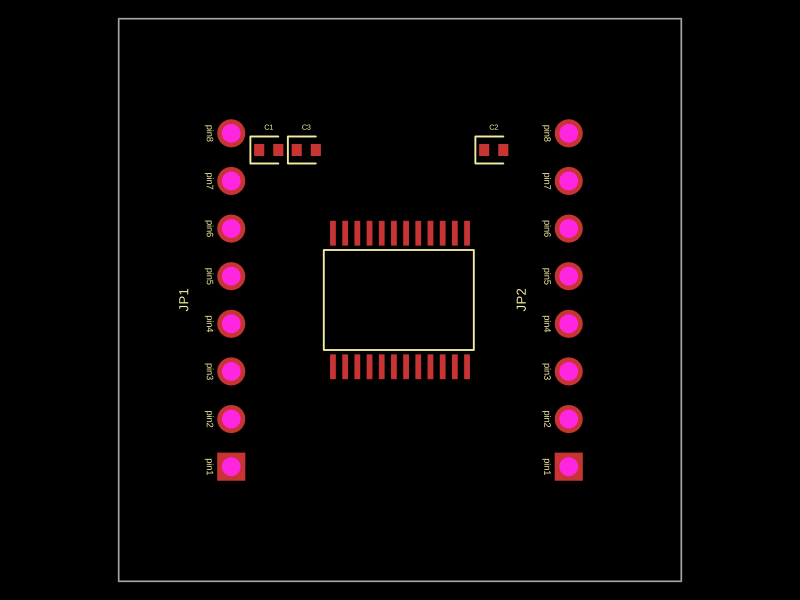 Similar packageimrishabh18/motor-driver-breakout"A 30x30mm TB6612FNG motor driver board with dual 8-pin headers and bypass capacitors for motor control and power regulation"
This summary captures the key physical characteristics:
- Uses TB6612FNG motor driver chip
- 30x30mm board size
- Dual 8-pin headers (JP1 and JP2)
- Includes decoupling capacitors (C1, C2, C3)
- Purpose is motor control and power management
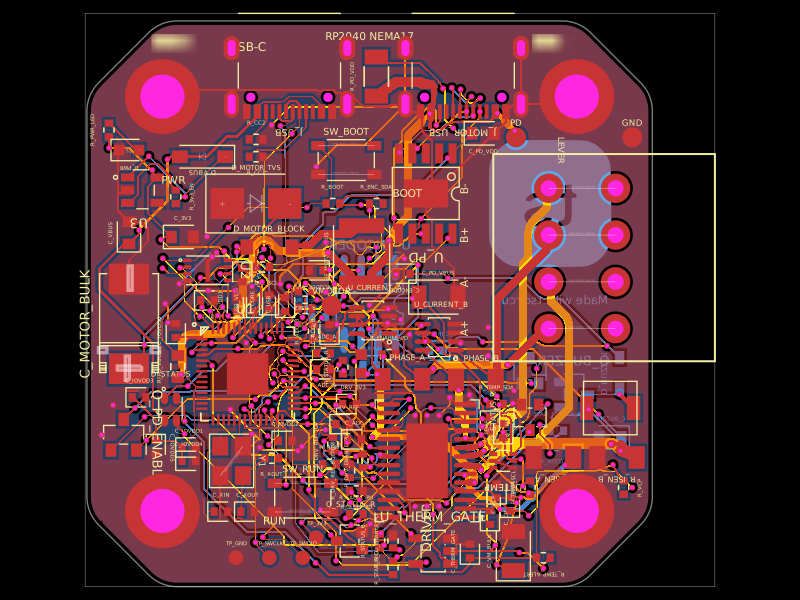 Discover something newastra/nema17-stepper-motor-controller-spring-clamp-rp2040A 4-layer RP2040 controller board that negotiates USB‑C PD motor power and drives a NEMA17 stepper via a DRV8825, with current sensing, thermal shutdown, RGB status LED, buzzer alarm, optional AS5600 encoder, protection/filtering, and test points.