astra/nema17-stepper-motor-controller-spring-clamp-rp2040
A 4-layer RP2040 controller board that negotiates USB‑C PD motor power and drives a NEMA17 stepper via a DRV8825, with current sensing, thermal shutdown, RGB status LED, buzzer alarm, optional AS5600 encoder, protection/filtering, and test points.
- Version
- 1.4.0
- License
- unset
- Stars
- 0
routing/README.md
# Fixed PCB routing

`route-plan.json` stores the complete four-layer NEMA 17 routing solution and the exact input geometry, connectivity and design rules used to validate it. `saved-routing.ts` supplies this geometry through tscircuit's local `algorithmFn` interface. Core recreates copper, vias and pours and performs its normal checks.

The whole board, including the RP2040 group and four grounded mounting rings, is routed together. Pipeline 7 produced the initial topology. Its power/signal expansion phases widened the copper; local geometry corrections removed a reset/signal crossing and a gate-pad clearance violation. A missing layer transition was represented by a physical through via. The motor header uses a round pin-1 pad to avoid a rotated rectangular-pad inconsistency between pour generation and Gerber export.

The saved plan rejects input changes. After changing placement, nets, footprints or routing rules, regenerate and validate the routes; do not merely replace `expectedInput`. Run `bun run verify` and inspect the placement/short-check reports before sharing fabrication files. See `../verification.md` for the exact checked artifact.
Related Packages
 More from this authorastra/am3352-ram-test-blankA 324-ball TI AM3352 ARM processor/SoC footprint with DDR, LCD, USB, Ethernet, MMC, GPMC, serial, SPI/I²C, audio, ADC, clock, power, and JTAG interfaces, plus DDR routing constraints.
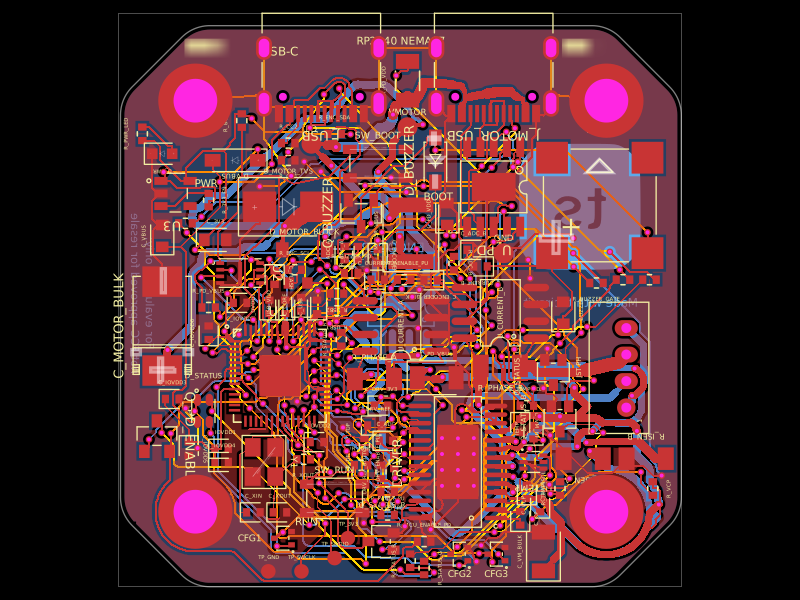 Similar packageimrishabh18/rp2040-motor-controllerA four-layer RP2040-based NEMA17 stepper controller with USB-C power/data, CH224K USB-PD negotiation, DRV8825 dual H-bridge drive, current/temperature telemetry, RGB status LED, buzzer alarm, QSPI flash, and optional AS5600 encoder.
 Discover something newMustafaMulla29/wireless-mouse-pcbA hardware component library defining footprints and 3D models for a 3.3 V regulator, RF antenna, switches, connectors, battery charger, and nRF52810 Bluetooth microcontroller.