astra/nema17-stepper-motor-controller-spring-clamp-rp2040
A 4-layer RP2040 controller board that negotiates USB‑C PD motor power and drives a NEMA17 stepper via a DRV8825, with current sensing, thermal shutdown, RGB status LED, buzzer alarm, optional AS5600 encoder, protection/filtering, and test points.
- Version
- 1.4.0
- License
- unset
- Stars
- 0
firmware/current_monitor.py
"""Signed winding-current telemetry for INA241A1 + 0.1 ohm inline shunts.

Gain is 10 V/V, so sensitivity is 1 V/A. REF1=3V3, REF2=GND.
These readings are short-window signed averages, not RMS or stall detection.
ADC reference is nominally 3.3 V; calibrate against a meter on real hardware.
"""

ADC_FULL_SCALE = 65535
ADC_REFERENCE_V = 3.3
SENSITIVITY_V_PER_A = 10 * 0.1


def current_amperes(raw, zero=ADC_FULL_SCALE / 2, reference_v=ADC_REFERENCE_V):
    if not 0 <= raw <= ADC_FULL_SCALE:
        raise ValueError("ADC value out of range")
    return (raw - zero) * reference_v / ADC_FULL_SCALE / SENSITIVITY_V_PER_A


class CurrentMonitor:
    def __init__(self, adc_a, adc_b):
        self.adcs = (adc_a, adc_b)
        self.zero = [ADC_FULL_SCALE / 2, ADC_FULL_SCALE / 2]
        self.amperes = (None, None)
        self.clipped = False

    def sample(self, count=32):
        if count < 1 or count > 256:
            raise ValueError("invalid sample count")
        totals = [0, 0]
        clipped = False
        for _ in range(count):
            for i, adc in enumerate(self.adcs):
                raw = adc.read_u16()
                # Flag lost measurement range; don't present saturation as valid current.
                clipped = clipped or raw < 1024 or raw > ADC_FULL_SCALE - 1024
                totals[i] += raw
        self.clipped = clipped
        self.amperes = tuple(current_amperes(totals[i] / count, self.zero[i]) for i in range(2))
        return self.amperes
Related Packages
 More from this authorastra/am3352-ram-test-blankA 324-ball TI AM3352 ARM processor/SoC footprint with DDR, LCD, USB, Ethernet, MMC, GPMC, serial, SPI/I²C, audio, ADC, clock, power, and JTAG interfaces, plus DDR routing constraints.
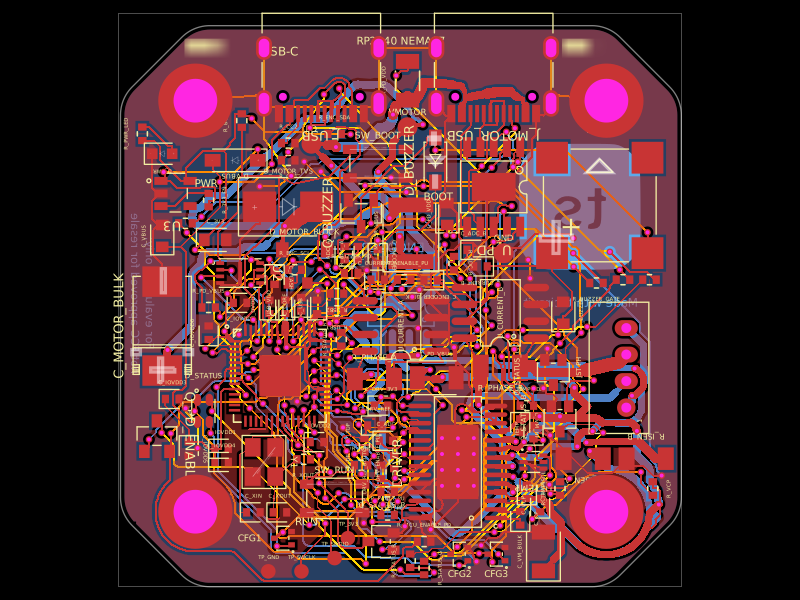 Similar packageimrishabh18/rp2040-motor-controllerA four-layer RP2040-based NEMA17 stepper controller with USB-C power/data, CH224K USB-PD negotiation, DRV8825 dual H-bridge drive, current/temperature telemetry, RGB status LED, buzzer alarm, QSPI flash, and optional AS5600 encoder.
 Discover something newMustafaMulla29/wireless-mouse-pcbA hardware component library defining footprints and 3D models for a 3.3 V regulator, RF antenna, switches, connectors, battery charger, and nRF52810 Bluetooth microcontroller.