AnasSarkiz/NEMA14_CH32X035G8U6
A NEMA stepper motor is shown with proposed M3 screws/spacers, four wired motor leads and splices, and a JST SHR-04V-S connector.
- Version
- 1.12.2
- License
- ISC
- Stars
- 0
scripts/check-mechanical-mounts.py
import pathlib,json,hashlib,itertools,math,sys
import cadquery as cq
from shapely.geometry import Point,LineString,Polygon,box
from shapely import affinity
from shapely.ops import unary_union
root=pathlib.Path(__file__).resolve().parents[1];source=root/(sys.argv[1] if len(sys.argv)>1 else 'artifacts/board.circuit.json');board_bytes=source.read_bytes();j=json.loads(board_bytes);cat=json.loads((root/'src/jlcpcb-catalog.json').read_text());src={e['source_component_id']:e for e in j if e['type']=='source_component'};parts={};cache={};meta={};conservative_models=[]
bound_cache={}
def bounds(s):
 if id(s) in bound_cache:return bound_cache[id(s)]
 b=s.BoundingBox();bound_cache[id(s)]= [getattr(b,k) for k in ['xmin','ymin','zmin','xmax','ymax','zmax']]
 return bound_cache[id(s)]
def broad(a,b):
 x,y=bounds(a),bounds(b);return all(x[i+3]>=y[i] and y[i+3]>=x[i] for i in range(3))
def bbox_distance(a,b):
 x,y=bounds(a),bounds(b)
 return math.sqrt(sum(max(x[i]-y[i+3],y[i]-x[i+3],0)**2 for i in range(3)))
def nearest_distance(a,others):
 # A far compound-distance query can return an invalid zero in this OCCT
 # build. Bounding-box lower bounds safely exclude distant candidates.
 best=float('inf')
 for b in sorted(others,key=lambda q:bbox_distance(a,q)):
  lower=bbox_distance(a,b)
  if lower>=best:continue
  d=a.distance(b)
  assert d+1e-5>=lower, 'Native STEP distance contradicts its geometric lower bound'
  best=min(best,d)
 return best
def volume(a,b):return max(0,a.copy().intersect(b.copy()).Volume()) if broad(a,b) else 0

dnp={e['source_component_id'] for e in j if e['type']=='pcb_component' and e.get('do_not_place')}
for m in j:
 if m.get('source_component_id') in dnp:continue
 if m['type']!='cad_component' or not m.get('model_step_url'):continue
 name=src[m['source_component_id']]['name'];p=cat['parts'][cat['components'][name]];f=root/next(f for f in p['modelFiles'] if f.endswith('.step'));assert hashlib.sha256(f.read_bytes()).hexdigest()==p['sha256']['step']
 if str(f) not in cache:cache[str(f)]=cq.importers.importStep(str(f)).val()
 s=cache[str(f)];assert len(s.Solids())>0
 if not s.isValid():
  assert name in ['J_PD','J_DATA'] and src[m['source_component_id']]['manufacturer_part_number']=='USB4145-03-0070-C', 'Unexpected invalid supplier STEP'
  b=s.BoundingBox();s=cq.Workplane('XY').box(b.xlen,b.ylen,b.zlen).val().translate(((b.xmin+b.xmax)/2,(b.ymin+b.ymax)/2,(b.zmin+b.zmax)/2))
  conservative_models.append({'reference':name,'reason':'Native supplier STEP fails OCCT validity; collision screen uses its complete bounding solid as an over-approximation, never exact boolean geometry.','original_STEP_sha256':p['sha256']['step']})
 o=m['model_origin_position'];s=s.translate(tuple(-o[k] for k in 'xyz'))
 for axis,vec in [('x',(1,0,0)),('y',(0,1,0)),('z',(0,0,1))]:
  if m['rotation'][axis]:s=s.rotate((0,0,0),vec,m['rotation'][axis])
 s=s.translate(tuple(m['position'][k] for k in 'xyz'));parts[name]=s;meta[name]=m
 print('Imported',name,flush=True)
assert set(parts)==set(cat['components'])-{src[k]['name'] for k in dnp}, 'Every fitted part requires its original STEP model'
heads={str((x,y)):cq.Workplane('XY').circle(3.2).extrude(3).val().translate((x,y,.8)) for x,y in itertools.product([-13,13],repeat=2)}
intersections=[];clearances=[]
for (a,s),(b,t) in itertools.combinations(parts.items(),2):
 if broad(s,t):
  print('Intersect',a,b,flush=True)
  v=volume(s,t)
  if v>1e-5:intersections.append({'a':a,'b':b,'volume_mm3':v})
for a,s in parts.items():
 for b,t in heads.items():
  x,y=bounds(s),bounds(t)
  lower=math.sqrt(sum(max(x[i]-y[i+3],y[i]-x[i+3],0)**2 for i in range(3)))
  if lower>=1:continue
  d=s.distance(t)
  if d<1:clearances.append({'reference':a,'mount':b,'distance_to_radius3p2_fastener_mm':d,'intersection_mm3':volume(s,t)})
tools={name:cq.Workplane('XY').circle(3).extrude(25).val().translate((x,y,3.8)) for name,(x,y) in zip(heads,itertools.product([-13,13],repeat=2))}
tool_collisions=[]
for mount,tool in tools.items():
 for name,part in parts.items():
  v=volume(tool,part)
  if v>1e-5:tool_collisions.append({'mount':mount,'reference':name,'intersection_mm3':v})
plugs={};usb=[]
for name in ['J_PD','J_DATA']:
 m=meta[name];bb=bounds(parts[name]);mouth=[(bb[0]+bb[3])/2,(bb[1]+bb[4])/2,bb[5]];direction=[0,0,1]
 assert m['rotation']['x']==m['rotation']['y']==m['rotation']['z']==0
 # Upright connector: 10 mm wide, 7 mm deep housing, 30 mm vertical grip/cable envelope.
 # A 0.5 mm seating overlap is allowed only with its own connector.
 plug=cq.Workplane('XY').box(10,7,30).val().translate((mouth[0],mouth[1],mouth[2]+14.5));plugs[name]=plug
 collisions=[]
 for n,s in list(parts.items())+list(heads.items()):
  if n!=name and broad(plug,s):
   v=volume(plug,s)
   if v>1e-5:collisions.append({'other':n,'volume_mm3':v})
 usb.append({'native_body_to_mount_envelope_mm':nearest_distance(parts[name],heads.values()),'reference':name,'mouth_xyz_mm':mouth,'mouth_xy_mm':mouth[:2],'insertion_direction':'+Z','outward_unit_vector':direction,'plug_10x7x30mm_intersections':collisions,'bbox_mm':bounds(parts[name])})
plug_intersections=[]
for (a,s),(b,t) in itertools.combinations(plugs.items(),2):
 v=volume(s,t)
 if v>1e-5:plug_intersections.append({'a':a,'b':b,'volume_mm3':v})
for mount,tool in tools.items():
 for name,plug in plugs.items():
  v=volume(tool,plug)
  if v>1e-5:tool_collisions.append({'mount':mount,'reference':name+'_plug','intersection_mm3':v})
plug_gap=plugs['J_PD'].distance(plugs['J_DATA'])
assert plug_gap >= 2.09999, 'Simultaneous 10 mm housings must retain at least 2.1 mm separation'
# PH is a top-entry connector. Verify actual STEP leads, PCB envelope, and an unobstructed vertical insertion region.
motor=parts['J_MOTOR'];motor_meta=meta['J_MOTOR'];motor_pcb=next(e for e in j if e['type']=='pcb_component' and e['source_component_id']==motor_meta['source_component_id'])
motor_pads=[e for e in j if e['type']=='pcb_smtpad' and e['pcb_component_id']==motor_pcb['pcb_component_id']]
assert len(motor_pads)==6 and not any(e['type']=='pcb_plated_hole' and e['pcb_component_id']==motor_pcb['pcb_component_id'] for e in j)
# The supplier STEP fuses contacts/plastic into one solid; it cannot prove
# separate metal-terminal centers. Verify occupied STEP landing regions for
# all six native pads, the absence of underside tails, and body/access clearance.
lead_alignment=[]
for pad in motor_pads:
 region=cq.Workplane('XY').box(pad['width'],pad['height'],.1).val().translate((pad['x'],pad['y'],.85))
 overlap=volume(motor,region)
 assert overlap>1e-5, 'Native JST STEP has no landing geometry over a copper pad'
 lead_alignment.append({'native_pad_xy_mm':[pad['x'],pad['y']],'STEP_landing_region_volume_mm3':overlap,'individual_metal_terminal_center_verified':False})
assert bounds(motor)[2]>=.79999, 'SMT JST must not project below the top PCB surface'
mb=bounds(motor);assert all(-17.5<=mb[i]<=17.5 for i in [0,1,3,4]), 'JST body exceeds the fixed PCB outline'
# This screen adds 0.3 mm around the actual header's XY bounds. It proves free space above the header, not a qualified cable or finger/grip envelope.
mx=(mb[0]+mb[3])/2;my=(mb[1]+mb[4])/2
access=cq.Workplane('XY').box(mb[3]-mb[0]+.6,mb[4]-mb[1]+.6,20).val().translate((mx,my,mb[5]+10))
access_collisions=[]
for name,other in list(parts.items())+list(heads.items())+list(plugs.items())+list(('tool_'+name,tool) for name,tool in tools.items()):
 if name=='J_MOTOR':continue
 v=volume(access,other)
 if v>1e-5:access_collisions.append({'other':name,'volume_mm3':v})
motor_report={'reference':'J_MOTOR','manufacturer_part_number':'BM04B-SRSS-TB(LF)(SN)','supplier_id':'C160390','mating_housing':'SHR-04V-S','insertion_direction':'+Z (from above)','body_and_lead_bbox_mm':mb,'body_within_35mm_outline':True,'native_SMT_pad_centres_mm':[[p['x'],p['y']] for p in motor_pads],'native_JST_drills':0,'STEP_landing_regions':lead_alignment,'individual_STEP_metal_terminal_centers_verified':False,'vertical_access_envelope_bbox_mm':bounds(access),'vertical_access_intersections':access_collisions,'tail_projection_below_PCB_mm':max(0,-.8-mb[2]),'cable_and_finger_clearance_hardware_tested':False}
report={'source_path':str(source),'fastener_requirement':{'standard':'Envelope requirement; exact fastener SKU unqualified','thread':'M3','maximum_head_diameter_mm':6,'model_envelope_diameter_mm':6.4,'conservative_model_height_mm':3,'radial_screen_allowance_mm':.2},'vertical_driver_access':{'tool_shaft_diameter_mm':6,'starts_at_z_mm':3.8,'height_mm':25,'collisions':tool_collisions,'actual_driver_tool_verified':False},'plug_pair_intersections':plug_intersections,'minimum_simultaneous_plug_gap_mm':plug_gap,'board_sha256':hashlib.sha256(board_bytes).hexdigest(),'unpopulated_bottom_references':sorted(src[k]['name'] for k in dnp),'optional_encoder_rear_fit_verified':False,'native_STEP_models':len(parts),'conservative_USB_bounding_models':conservative_models,'component_intersections':intersections,'fastener_clearances':clearances,'usb':usb,'mounts':[[x,y] for x,y in itertools.product([-13,13],repeat=2)],'motor_connector':motor_report,'rear_motor_compatibility_verified':False,'limitations':['Supplier JST STEP fuses plastic and contacts; six landing-region overlaps are checked, individual metal-terminal centers require datasheet/assembler confirmation.','Nominal PCB/model screen only; no verified mounting to rear motor endcap.','Cable envelope is a defined 10x7x30 mm procurement bound, not tested cable hardware.','Ø6.4 mm fastener envelope is a defined screen budget around maximum Ø6 mm heads; complete assembly tolerance, torque, thread engagement and any washer/spacer are unqualified.']}
out=root/'artifacts/mechanical';out.mkdir(exist_ok=True);assert source.read_bytes()==board_bytes, 'Board changed during mechanical audit'
report['passed']=not tool_collisions and not access_collisions and not intersections and not plug_intersections and all(e['intersection_mm3']<1e-5 for e in clearances) and all(not e['plug_10x7x30mm_intersections'] for e in usb)
(out/('source-mount-usb-screen.json' if len(sys.argv)>1 else 'mount-usb-screen.json')).write_text(json.dumps(report,indent=2)+'\n');print(json.dumps(report,indent=2))

raise SystemExit(0 if report['passed'] else 1)
Related Packages
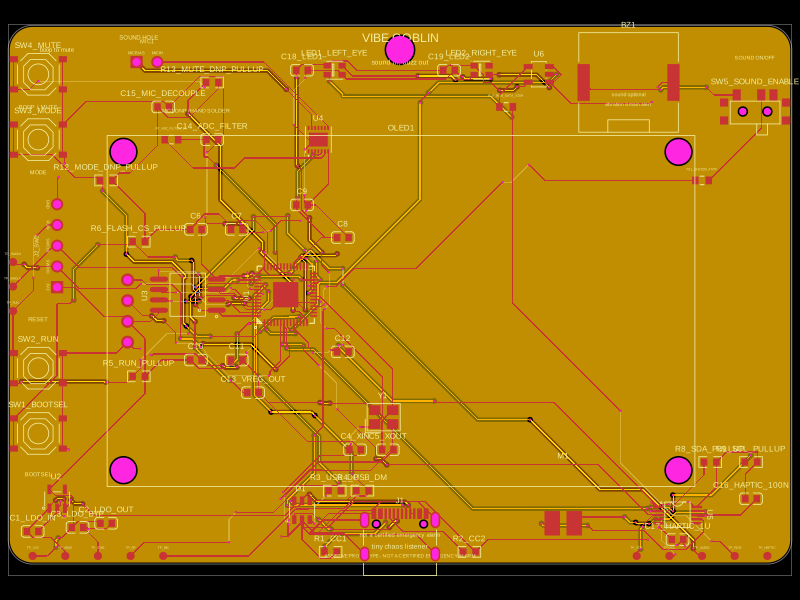 More from this authorAnasSarkiz/vibe_GoblinThese code snippets define various physical electronic components such as ICs, connectors, sensors, LEDs, and chips, specifying their pin layouts, footprint pads, silkscreen markings, courtyard outlines, and 3D CAD models for placement on PCB boards.
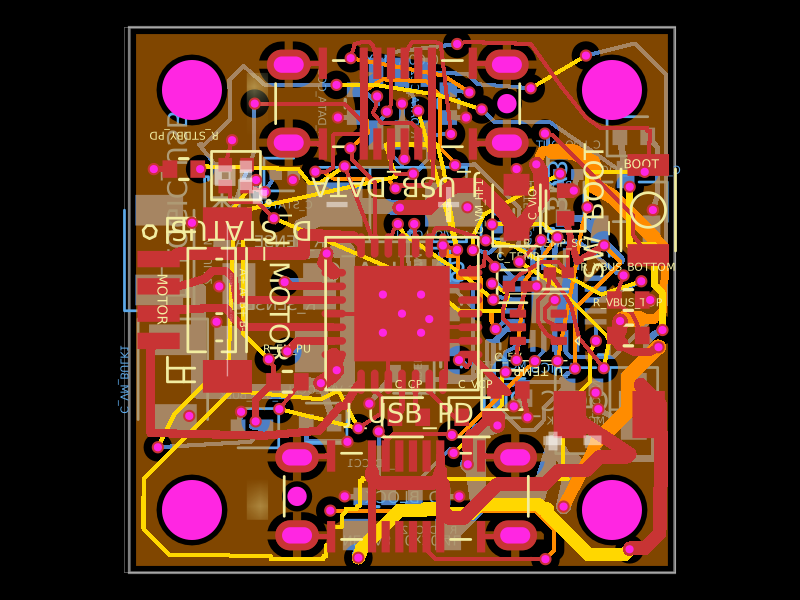 Similar packageShiboSoftwareDev/nema8-20mm-dual-usbc-stepper-controllerA compact 20 mm four-layer USB‑C stepper-controller PCB combining CH32X035 MCU control, TMC2209 motor driving, USB‑C PD/data interfaces, protection/power regulation, temperature/LED status hardware, and NEMA8 motor connectivity.
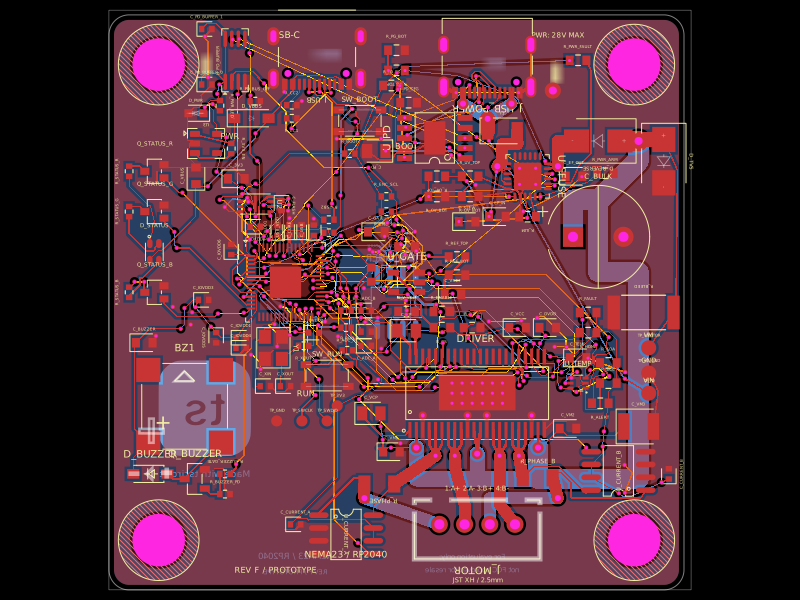 Discover something newimrishabh18/nema-23-stepper-controllerA four-layer NEMA23 stepper motor controller PCB featuring an RP2040 MCU, DRV8452 dual-phase driver, USB‑C PD power input/protection, current and temperature sensing, status LED/buzzer, and optional magnetic encoder.