AnasSarkiz/NEMA14_CH32X035G8U6
A NEMA stepper motor is shown with proposed M3 screws/spacers, four wired motor leads and splices, and a JST SHR-04V-S connector.
- Version
- 1.12.2
- License
- ISC
- Stars
- 0
imports/supplier/SRN4018_4R7M/SRN4018_4R7M.tsx
import React from "react"
const objPath = "https://raw.githubusercontent.com/AnasSarkiz/NEMA17_Controller/9bcde14e6865e6719d26c354127052890d848067/imports/supplier/SRN4018_4R7M/SRN4018_4R7M.obj"
const stepPath = "https://raw.githubusercontent.com/AnasSarkiz/NEMA17_Controller/9bcde14e6865e6719d26c354127052890d848067/imports/supplier/SRN4018_4R7M/SRN4018_4R7M.step"
import type { InductorProps } from "@tscircuit/props"

export const SRN4018_4R7M = (props: Omit<InductorProps, "inductance">) => {
  return (
    <inductor
      inductance="4.7uH"
      supplierPartNumbers={{
  "jlcpcb": [
    "C780206"
  ]
}}
      manufacturerPartNumber="SRN4018-4R7M"
      footprint={<footprint>
        <smtpad portHints={["pin1"]} pcbX="-1.400048mm" pcbY="0mm" width="1.3999972mm" height="4.1999916mm" shape="rect" />
<smtpad portHints={["pin2"]} pcbX="1.400048mm" pcbY="0mm" width="1.3999972mm" height="4.1999916mm" shape="rect" />
<silkscreenpath route={[{"x":-2.286000000000058,"y":2.5399999999999636},{"x":2.4129999999998972,"y":2.5399999999999636},{"x":2.4129999999998972,"y":-2.286000000000058},{"x":2.4129999999998972,"y":-2.413000000000011},{"x":-2.286000000000058,"y":-2.413000000000011},{"x":-2.413000000000011,"y":-2.413000000000011},{"x":-2.413000000000011,"y":2.5399999999999636},{"x":-2.286000000000058,"y":2.5399999999999636}]} />
<silkscreentext text="{NAME}" pcbX="0mm" pcbY="3.54mm" anchorAlignment="center" fontSize="1mm" />
<courtyardoutline outline={[{"x":-2.3500466000000415,"y":2.349995799999988},{"x":2.350046599999928,"y":2.349995799999988},{"x":2.350046599999928,"y":-2.349995799999988},{"x":-2.3500466000000415,"y":-2.349995799999988},{"x":-2.3500466000000415,"y":2.349995799999988}]} />
      </footprint>}
      cadModel={{
        objUrl: objPath,
        positionOffset: { x: (0.0) * Math.cos(Number(props.pcbRotation ?? 0) * Math.PI / 180) - (0.0) * Math.sin(Number(props.pcbRotation ?? 0) * Math.PI / 180), y: (0.0) * Math.sin(Number(props.pcbRotation ?? 0) * Math.PI / 180) + (0.0) * Math.cos(Number(props.pcbRotation ?? 0) * Math.PI / 180), z: 0 },
        stepUrl: stepPath,
        pcbRotationOffset: 0,
        modelOriginPosition: { x: 0, y: 0.02499999999999991, z: -0.02 },
      }}
      {...props}
    />
  )
}
Related Packages
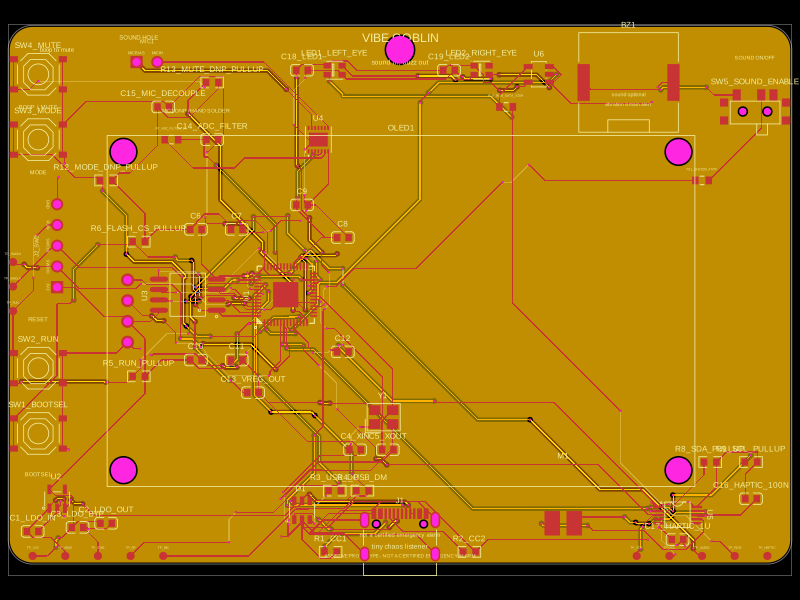 More from this authorAnasSarkiz/vibe_GoblinThese code snippets define various physical electronic components such as ICs, connectors, sensors, LEDs, and chips, specifying their pin layouts, footprint pads, silkscreen markings, courtyard outlines, and 3D CAD models for placement on PCB boards.
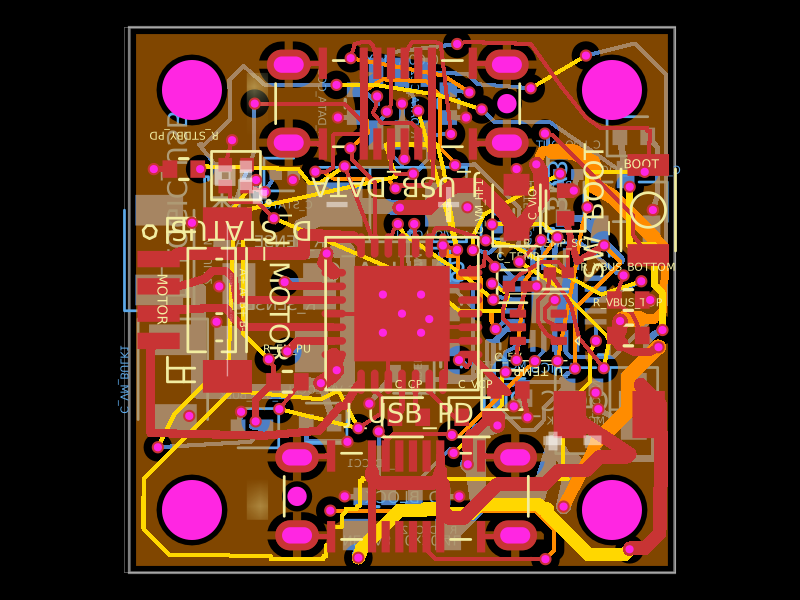 Similar packageShiboSoftwareDev/nema8-20mm-dual-usbc-stepper-controllerA compact 20 mm four-layer USB‑C stepper-controller PCB combining CH32X035 MCU control, TMC2209 motor driving, USB‑C PD/data interfaces, protection/power regulation, temperature/LED status hardware, and NEMA8 motor connectivity.
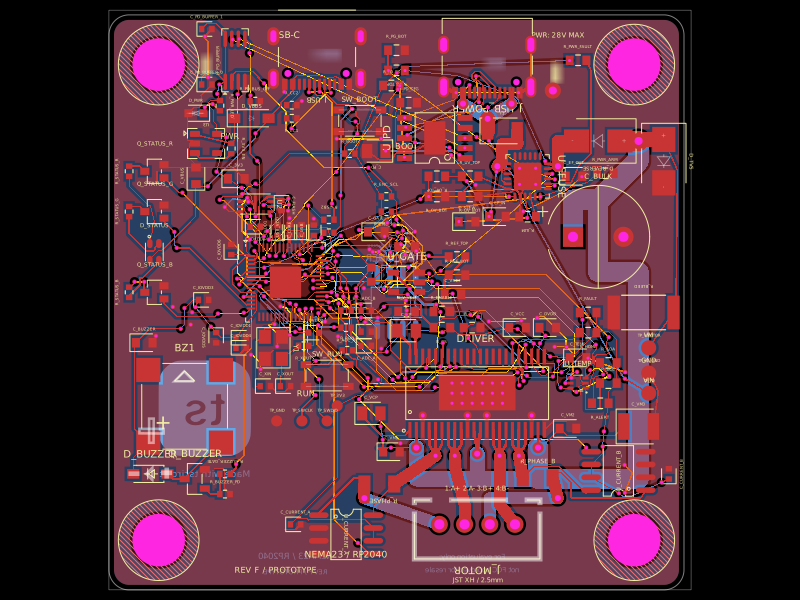 Discover something newimrishabh18/nema-23-stepper-controllerA four-layer NEMA23 stepper motor controller PCB featuring an RP2040 MCU, DRV8452 dual-phase driver, USB‑C PD power input/protection, current and temperature sensing, status LED/buzzer, and optional magnetic encoder.