AnasSarkiz/NEMA14_CH32X035G8U6
A NEMA stepper motor is shown with proposed M3 screws/spacers, four wired motor leads and splices, and a JST SHR-04V-S connector.
- Version
- 1.12.2
- License
- ISC
- Stars
- 0
docs/firmware-interface.md
> Historical baseline document: this predates the opposite-edge v1.11.0 draft. See [current draft and blockers](opposite-edge-review.md) for current evidence.

# Firmware interface (hardware contract; implementation pending)

| Signal | CH32X035G8U6 pad | GPIO | Requirement |
| --- | --- | --- | --- |
| STEP | 5 | PA0 | Timer-driven pulses, ≥2 µs high and ≥2 µs low |
| DIR | 6 | PA1 | Hold stable ≥2 µs before STEP edge |
| PD_GOOD | 7 | PA2 | Active-low CH224K PG; pull-up to 3.3 V |
| DATA_PRESENT | 8 | PA3 | 100 kΩ/100 kΩ divider from computer VBUS |
| VM_SENSE | 9 | PA4 | 100 kΩ/10 kΩ divider; 15 V → 1.364 V; ADC full scale is not a safe overvoltage limit |
| ENABLE_N | 14 | PB3 | High disables driver; hardware default high |
| SLEEP | 15 | PB4 | Low disables bridge/charge pump; hardware default low |
| DCK | 24 | PC19 | WCH two-wire programming clock |
| DIO | 25 | PC18 | WCH two-wire programming data |
| USB D− | 26 | PC16 | USBFS native PHY |
| USB D+ | 27 | PC17 | USBFS native PHY |

CH32X035G8U6 uses 3.3 V supply and its internal 48 MHz oscillator. USB firmware must select the MCU's **3.3 V PHY mode**, detect data-port VBUS, and use the native USB pull-up configuration; do not copy a 5 V-only example unchanged. The fixed PD trigger requires no MCU PD stack.

Startup sequence: initialize STEP low, ENABLE_N high, SLEEP low; read voltage and PG; expose USB only with data VBUS present; require an explicit host command; enable only with PG low and motor supply 13.5–16.5 V; raise SLEEP, wait at least 1 ms for the charge pump, then drive ENABLE_N low. A source without a 15 V PDO must leave the motor disabled. Stop on a lost PD contract, USB disconnect, or command watchdog timeout. Never automatically resume motion after reset.

A proposed USB CDC command interface is `STATUS`, `MOVE <signed microsteps> <microsteps/second>`, `STOP`, and `DISABLE`. Use a timer/state machine rather than blocking delays. Limit acceleration and speed through bench testing; winding current and available torque limit the useful rate. This file is a contract for the next firmware task, not tested firmware. WCH provides `EVT/EXAM/USB/USBFS/DEVICE/SimulateCDC` in its CH32X035 SDK; remove the example's USART2 bridge because PA2 is used here for PD power sensing. PA3 is used for computer-VBUS presence.

For factory ROM USB boot entry, see [USB programming](usb-programming.md). This hardware contract does not supply a motor-control application.

Motor voltage conversion: `VM_V = VM_SENSE_V × 11` for the reviewed 100 kΩ/10 kΩ divider. Update/calibrate firmware accordingly; the former ×(122/22) conversion is obsolete.
Related Packages
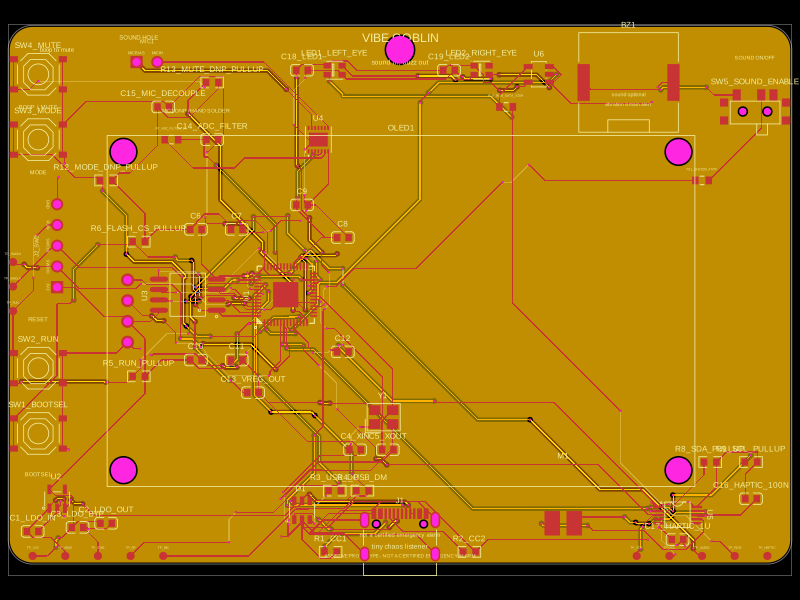 More from this authorAnasSarkiz/vibe_GoblinThese code snippets define various physical electronic components such as ICs, connectors, sensors, LEDs, and chips, specifying their pin layouts, footprint pads, silkscreen markings, courtyard outlines, and 3D CAD models for placement on PCB boards.
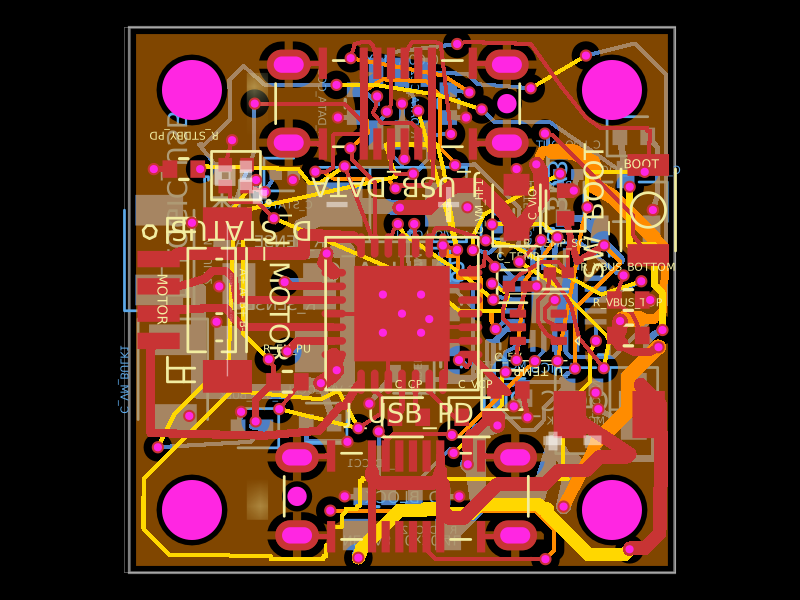 Similar packageShiboSoftwareDev/nema8-20mm-dual-usbc-stepper-controllerA compact 20 mm four-layer USB‑C stepper-controller PCB combining CH32X035 MCU control, TMC2209 motor driving, USB‑C PD/data interfaces, protection/power regulation, temperature/LED status hardware, and NEMA8 motor connectivity.
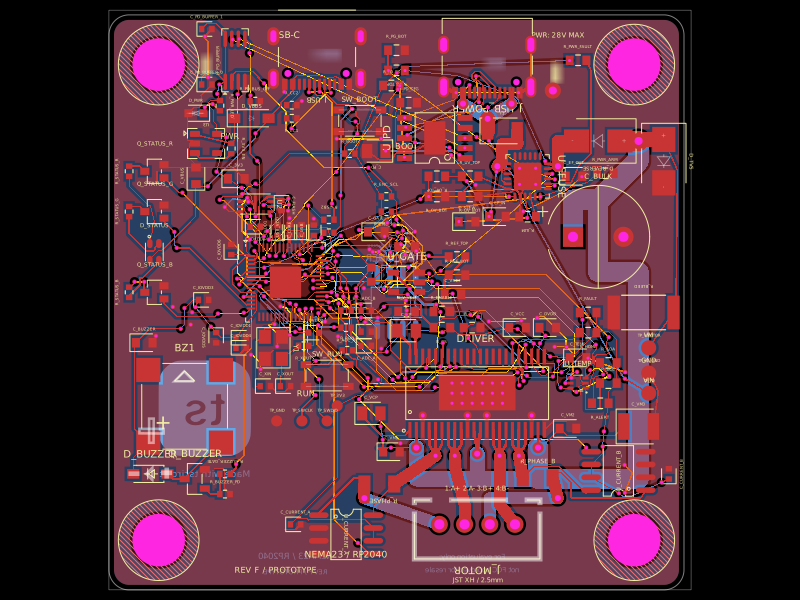 Discover something newimrishabh18/nema-23-stepper-controllerA four-layer NEMA23 stepper motor controller PCB featuring an RP2040 MCU, DRV8452 dual-phase driver, USB‑C PD power input/protection, current and temperature sensing, status LED/buzzer, and optional magnetic encoder.