mohan-bee/gimbal-one-budget-pcb
A 4-layer STM32-based gimbal controller PCB with an onboard LSM6DS3TR-C IMU, three DRV8313 3-phase motor drivers, protected 3S battery input, 3.3 V buck regulation, and SWD/UART control interfaces.
- Version
- 0.1.0
- License
- unset
- Stars
- 0
routing/check-routing.test.ts
import assert from "node:assert/strict"
import reference from "./reference-input.json"
import { checkedRouting } from "./checked-routing"
const router = await checkedRouting(structuredClone(reference))
assert.equal(router.solveSync().length,225)
for(const change of [
  (x:typeof reference)=>{x.bounds.maxX+=1},
  (x:typeof reference)=>{x.connections[0].pointsToConnect[0].x+=0.1},
  (x:typeof reference)=>{x.connections[0].name="CHANGED_NET"},
  (x:typeof reference)=>{x.obstacles[0].width+=0.1},
]){
  const changed=structuredClone(reference);change(changed)
  await assert.rejects(()=>checkedRouting(changed),/no longer matches/)
}
let completed=false
router.on("complete",()=>{completed=true});router.start()
await new Promise(resolve=>queueMicrotask(()=>resolve(undefined)))
assert.ok(completed)
console.log("PASS: saved routes load; changed board bounds, endpoints, nets and pad geometry are rejected.")
Related Packages
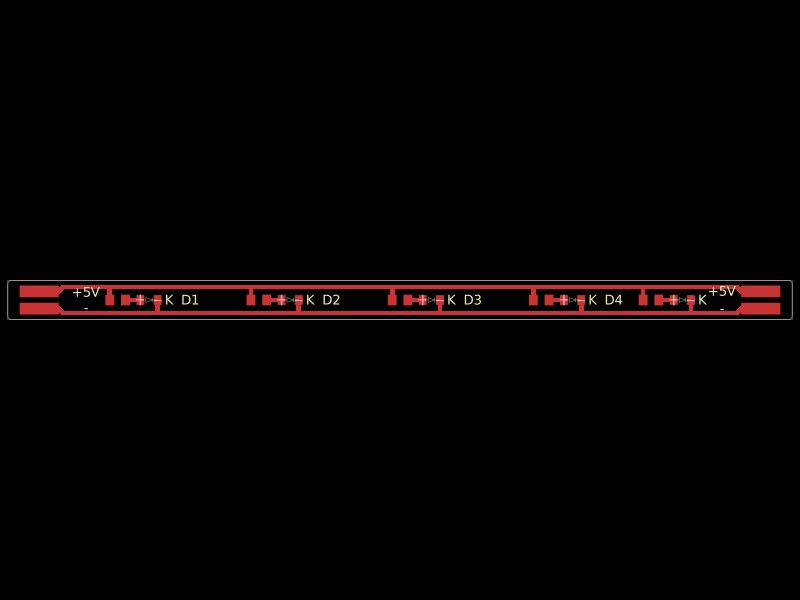 More from this authormohan-bee/warm5-flex-stripA 5 V flexible PCB strip with five parallel warm-white LED branches, each current-limited by a 330 Ω resistor, plus input/output power test terminals and pass-through connections.
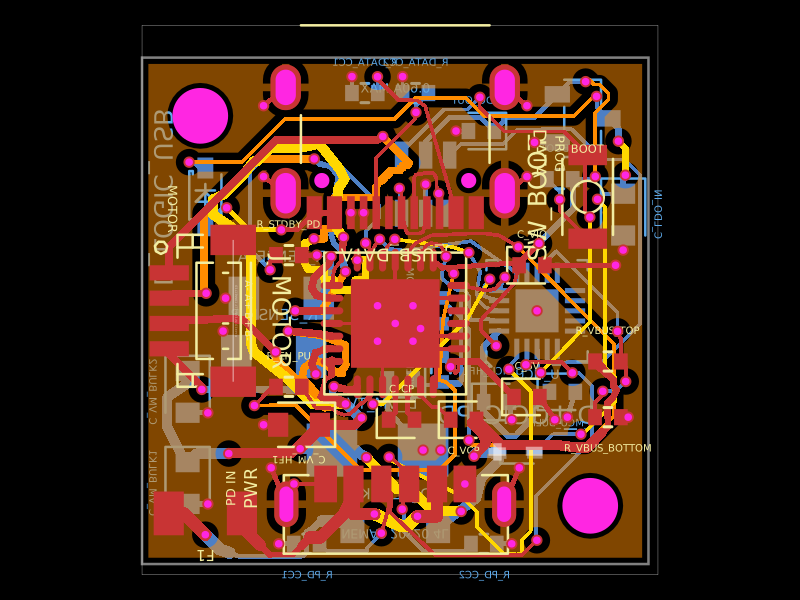 Similar packageShiboSoftwareDev/nema8-20mm-usbc-pd-controllerA 20×20 mm four-layer USB‑C PD stepper motor controller PCB using a CH32X035 MCU, TMC2209 driver, protected power inputs, USB data/boot interface, 3.3 V regulation, ESD/TVS protection, current-sense circuitry, and NEMA‑8 motor outputs.
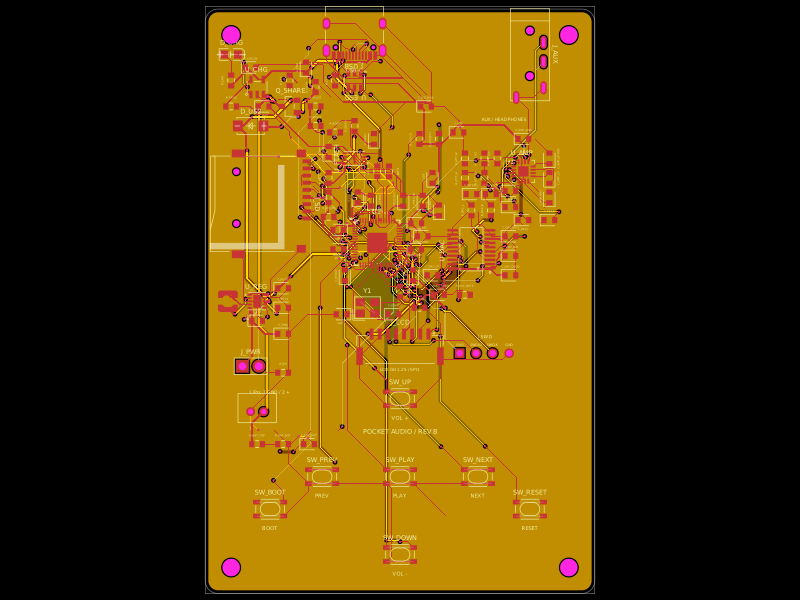 Discover something newDevesh36/pocket-audio-playerA portable, rechargeable microSD audio player built around an RP2040, SPI flash, USB‑C charging/power management, LCD/button controls, PCM5102A I²S DAC, and TPA6132A headphone amplifier in a 3D‑printed enclosure.