imrishabh18/nema17-motor-controller-flex
An RP2040-based USB‑C/USB‑PD controller board that powers and drives a NEMA17 stepper via a DRV8825, with current/temperature/voltage monitoring, optional AS5600 encoder, buzzer/RGB status indicators, QSPI flash, and flexible motor/encoder connections.
- Version
- 1.2.0
- License
- unset
- Stars
- 0
schematic/ProductionTestPoints.tsx
import placement from "../mechanical/next-placement.json";

/** Probe the negotiated PD rail and the post-fuse / reverse-blocking motor rail independently. */
export const ProductionTestPoints = () => (
  <>
    {([
      ["TP_PD", "PD", ".J_MOTOR_USB > .A4B9", 10.8, -7],
      ["TP_VMOTOR", "VMOTOR", ".D_MOTOR_BLOCK > .cathode", 14, -7],
      ["TP_PD_GND", "GND", "net.GND", 12, -10],
    ] as const).map(([name, label, target, schX, schY]) => (
      <group key={name} pcbX={0} pcbY={0}>
        <testpoint name={name} footprintVariant="pad" padShape="circle"
          padDiameter="1.5mm" layer="top" pcbStyle={{silkscreenTextVisibility:"hidden"}} {...placement[name]}
          schSheetName="motor_power" />
        <trace name={`${name}_TRACE`} from={`.${name} > .pin1`} to={target}
          schDisplayLabel={label} thickness="0.2mm" />
        <silkscreentext text={label} pcbX={placement[name].pcbX}
          pcbY={placement[name].pcbY + 1.1} fontSize="0.65mm" />
      </group>
    ))}
  </>
);
Related Packages
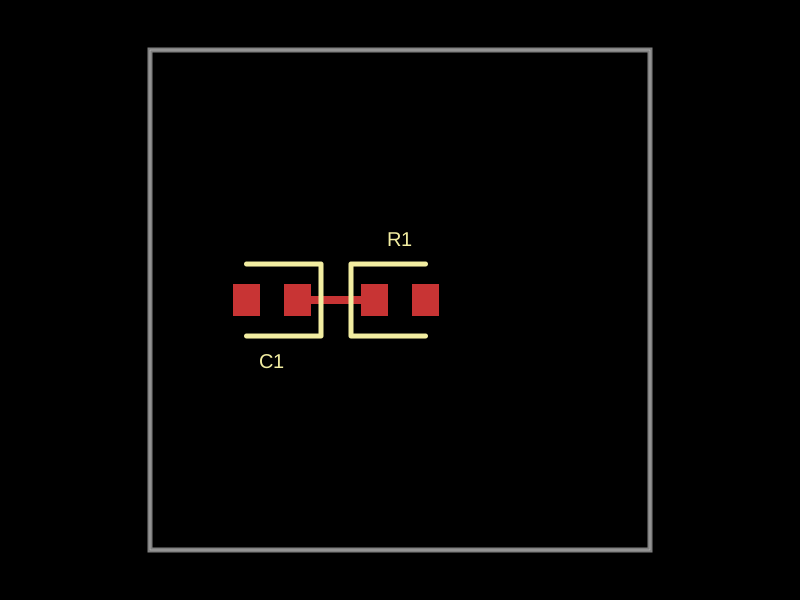 More from this authorimrishabh18/type-error-build-logThis code defines a 10mm by 10mm PCB layout with a 1kΩ resistor and a 1000pF capacitor connected by a trace, using 0402 surface-mount components.
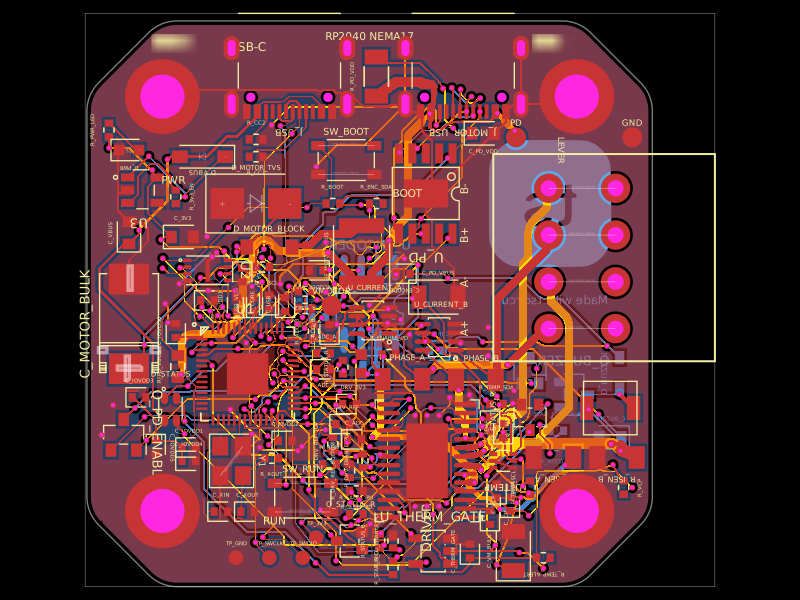 Similar packageastra/nema17-stepper-motor-controller-spring-clamp-rp2040A 4-layer RP2040 controller board that negotiates USB‑C PD motor power and drives a NEMA17 stepper via a DRV8825, with current sensing, thermal shutdown, RGB status LED, buzzer alarm, optional AS5600 encoder, protection/filtering, and test points.
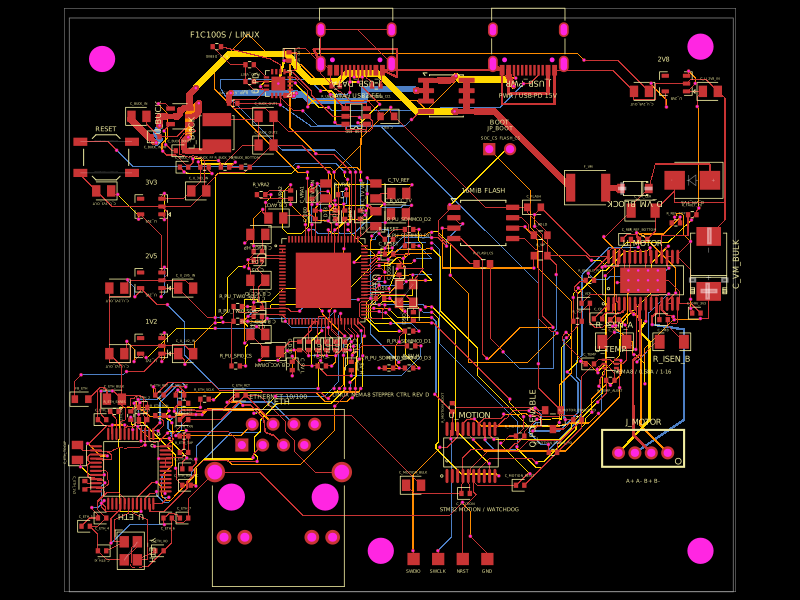 Discover something newshibosoftwaredev/f1c100s-linux-nema8-stepper-controllerRestores component part numbers and CAD models, removes test-point 3D bodies, and validates that solder paste exists only on top-side SMT pads without altering copper or DRC.