astra/nema17-stepper-motor-controller-spring-clamp-rp2040
A 4-layer RP2040 controller board that negotiates USB‑C PD motor power and drives a NEMA17 stepper via a DRV8825, with current sensing, thermal shutdown, RGB status LED, buzzer alarm, optional AS5600 encoder, protection/filtering, and test points.
- Version
- 1.4.0
- License
- unset
- Stars
- 0
firmware/audible_alarm.py
"""Passive buzzer driven through Q_BUZZER. No GPIO load current."""
from tmp102 import WARN_C, TRIP_C


def alarm_duty(temperature_c, hardware_alert_ok, now_ms):
    if not hardware_alert_ok or temperature_c is None or temperature_c >= TRIP_C:
        return 32768
    if temperature_c >= WARN_C:
        # Short chirp each second before shutdown temperature is reached.
        return 32768 if now_ms % 1000 < 200 else 0
    return 0


class AudibleAlarm:
    def __init__(self, pwm):
        self.pwm = pwm
        self.pwm.freq(4000)
        self.pwm.duty_u16(0)

    def update(self, temperature_c, hardware_alert_ok, now_ms):
        self.pwm.duty_u16(alarm_duty(temperature_c, hardware_alert_ok, now_ms))

    def close(self):
        self.pwm.duty_u16(0)
        self.pwm.deinit()
Related Packages
 More from this authorastra/am3352-sbcA four-layer AM3352 single-board computer with DDR3 memory, PMIC power management, USB-C PD 5V input, dual USB host ports, HDMI output, microSD/UART/JTAG interfaces, addressable RGB LEDs, and a PWM-driven buzzer.
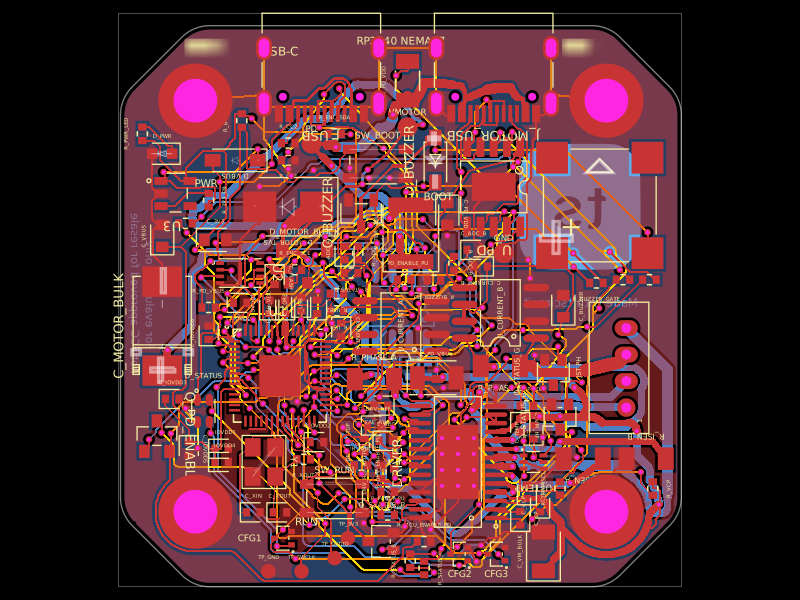 Similar packageimrishabh18/rp2040-motor-controllerAn RP2040-based NEMA17 stepper-motor controller with USB-C programming and PD motor-power negotiation, DRV8825 dual H-bridge drive, current/temperature telemetry, protected power filtering, status RGB LED, buzzer alarm, and optional magnetic encoder.
 Discover something newgokul/fieldkit-usbUSB-C-powered ESP32-S3 Wi-Fi/Bluetooth handheld with an SMD 128x32 OLED, six navigation buttons, USB-C power/data, complete checked routing, and four native schematic sheets.