AnasSarkiz/NEMA14_RP2040
A NEMA motor assembly concept with a controller board, four proposed M3 screws and spacers, motor lead splices, and a JST 4-pin connector harness.
- Version
- 1.13.0
- License
- ISC
- Stars
- 0
artifacts/opposite-edge/ordered-left-search.json
[
  {
    "ref": "U_MCU",
    "role": "GPIO6",
    "width": 0.16,
    "radius": 5,
    "future_corridors": [
      [
        [
          -1.3249360000000001,
          -0.600075
        ],
        [
          -2.1,
          -0.600075
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.399921
        ],
        [
          -2.1,
          -1.399921
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.799971
        ],
        [
          -2.1,
          -1.799971
        ]
      ],
      [
        [
          -1.3249360000000001,
          -2.200021
        ],
        [
          -2.1,
          -2.200021
        ]
      ]
    ]
  },
  {
    "ref": "U_MCU",
    "role": "GPIO7",
    "width": 0.16,
    "radius": 5,
    "future_corridors": [
      [
        [
          -1.3249360000000001,
          -0.200025
        ],
        [
          -2.1,
          -0.200025
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.399921
        ],
        [
          -2.1,
          -1.399921
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.799971
        ],
        [
          -2.1,
          -1.799971
        ]
      ],
      [
        [
          -1.3249360000000001,
          -2.200021
        ],
        [
          -2.1,
          -2.200021
        ]
      ]
    ]
  },
  {
    "ref": "U_MCU",
    "role": "GPIO8",
    "width": 0.16,
    "radius": 5,
    "future_corridors": [
      [
        [
          -1.3249360000000001,
          -0.200025
        ],
        [
          -2.1,
          -0.200025
        ]
      ],
      [
        [
          -1.3249360000000001,
          -0.600075
        ],
        [
          -2.1,
          -0.600075
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.799971
        ],
        [
          -2.1,
          -1.799971
        ]
      ],
      [
        [
          -1.3249360000000001,
          -2.200021
        ],
        [
          -2.1,
          -2.200021
        ]
      ]
    ]
  },
  {
    "ref": "U_MCU",
    "role": "GPIO9",
    "width": 0.16,
    "radius": 5,
    "future_corridors": [
      [
        [
          -1.3249360000000001,
          -0.200025
        ],
        [
          -2.1,
          -0.200025
        ]
      ],
      [
        [
          -1.3249360000000001,
          -0.600075
        ],
        [
          -2.1,
          -0.600075
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.399921
        ],
        [
          -2.1,
          -1.399921
        ]
      ],
      [
        [
          -1.3249360000000001,
          -2.200021
        ],
        [
          -2.1,
          -2.200021
        ]
      ]
    ]
  },
  {
    "ref": "U_MCU",
    "role": "GPIO10",
    "width": 0.16,
    "radius": 5,
    "future_corridors": [
      [
        [
          -1.3249360000000001,
          -0.200025
        ],
        [
          -2.1,
          -0.200025
        ]
      ],
      [
        [
          -1.3249360000000001,
          -0.600075
        ],
        [
          -2.1,
          -0.600075
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.399921
        ],
        [
          -2.1,
          -1.399921
        ]
      ],
      [
        [
          -1.3249360000000001,
          -1.799971
        ],
        [
          -2.1,
          -1.799971
        ]
      ]
    ]
  }
]
Related Packages
 More from this authorAnasSarkiz/testDefines a PCB layout with a JST PH 2-pin connector labeled "J1".
 Similar packageimrishabh18/rp2040-motor-controllerAn RP2040-based NEMA17 stepper-motor controller with USB-C programming and PD motor-power negotiation, DRV8825 dual H-bridge drive, current/temperature telemetry, protected power filtering, status RGB LED, buzzer alarm, and optional magnetic encoder.
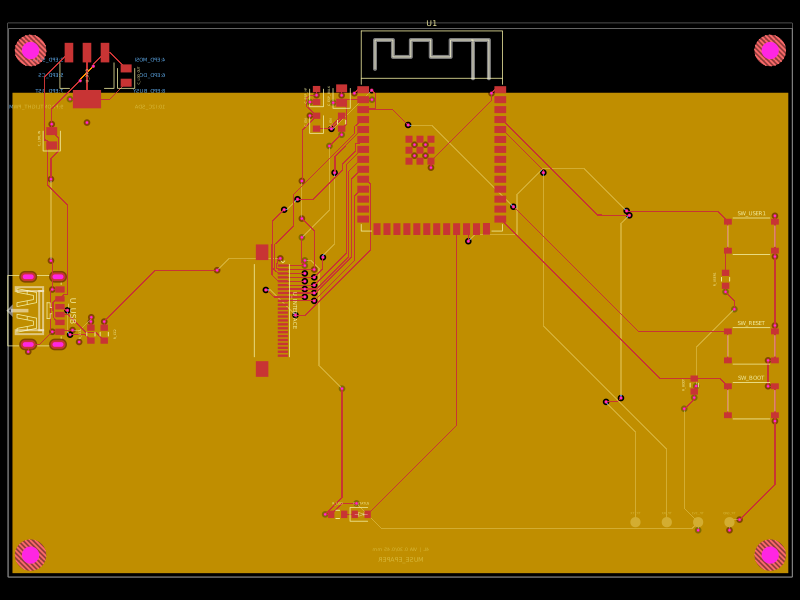 Discover something newShiboSoftwareDev/muse-reterminal-e1001-replacementA four-layer ESP32-S3 e-paper carrier board with USB-C power, AMS1117 3.3V regulation, 24-pin FFC interface, reset/boot and user buttons, status LED, decoupling passives, test points, mounting holes, and ground/power planes.